Noco tech Motor Noco tech Motor

7 Tips for Choosing the Right Precision Gear Motor?

Time:2026-10-28 Author:Oliver
0%

Choosing the right Precision Gear Motor can determine whether a machine runs smoothly or struggles under daily demand. A motor may appear suitable on paper, yet stall when loads change, temperatures rise, or startup cycles become frequent. Practical selection requires more than comparing speed and price.

This guide presents seven useful tips for evaluating gear motors in real operating conditions. It considers torque requirements, output speed, gear ratio, motor efficiency, duty cycle, noise, and installation space. Engineers should also examine backlash, shaft alignment, protection ratings, and expected service life. A compact conveyor, for example, may need steady torque at low speed rather than impressive peak power.

Details matter.

Reliable decisions usually combine manufacturer data, measured application demands, and advice from experienced suppliers. Request performance curves, thermal information, and clear tolerance specifications before approving a design. Testing a sample under realistic load can reveal problems that a catalog cannot show. It is not always convenient, but it prevents expensive changes later.

No selection method is perfect. Calculations can miss vibration, dust, poor lubrication, or unexpected starts. Even experienced teams may underestimate these factors. Reviewing the application after installation helps refine future choices and exposes weak assumptions. With careful verification, the right Precision Gear Motor can improve motion control, reduce maintenance pressure, and support dependable machine performance over time.
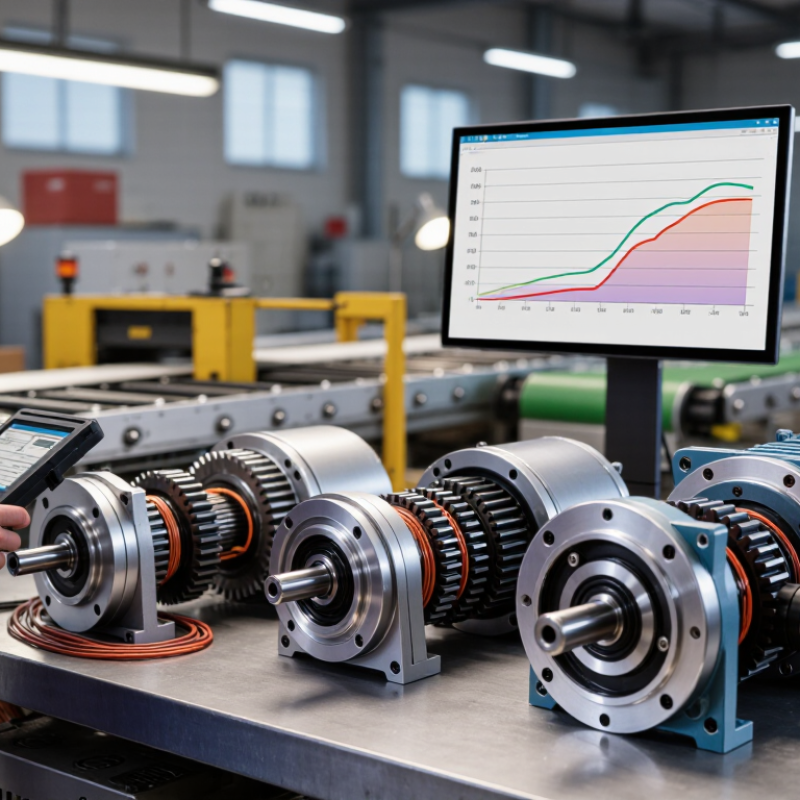
7 Tips for Choosing the Right Precision Gear Motor?

Define Load, Speed, and Torque Requirements with a 1.5–2× Service Factor

7 Tips for Choosing the Right Precision Gear Motor

Start with the load, not the motor catalog. Record the moving mass, friction, incline, duty cycle, and shock loads. Calculate torque at the shaft, then measure speed during acceleration and steady operation. A conveyor moving 40 kilograms at 30 revolutions per minute needs different gearing from a small indexing table at the same speed.

Apply a 1.5–2× service factor to the calculated torque. This margin covers starts, brief overloads, wear, and imperfect assumptions. It is not a universal rule. A clean spreadsheet can still miss sticky bearings or sudden jams. For frequent reversals, high inertia, or harsh duty, consult ISO 6336-based gear rating methods and the motor manufacturer’s thermal data.

The International Energy Agency estimates that motor-driven systems consume roughly half of global electricity, while the U.S. Department of Energy reports that industrial motor systems may use more than 70% of industrial electricity. Small efficiency gains matter.

Check continuous torque and peak torque separately. Confirm that the gearbox survives the peak load without excessive backlash. Then compare output speed, noise, mounting space, and control resolution. Leave room for temperature rise. Engineers sometimes select the largest motor “for safety,” but oversizing can reduce efficiency and control quality. Recheck the calculation after testing a prototype. Field data is often less tidy than the design model.

Compare Gear Types, Ratios, and Efficiency from 70% to 95%

Choosing a precision gear motor starts with the required output speed, torque, and duty cycle. A 10:1 ratio may reduce speed efficiently, but it can increase reflected load and backlash sensitivity. Helical gears commonly reach about 90%–95% efficiency, while planetary designs often approach 95% under suitable loading. Worm gears may fall between 70% and 90%, especially at high reduction ratios. Lower speed is not automatically better. Check whether the motor works near its rated load.

The U.S. Department of Energy’s Motor Systems Market Assessment reports that motor-driven equipment uses roughly 23% of U.S. electricity. The International Energy Agency also estimates that electric motors consume about 46% of global electricity. These figures make small efficiency differences commercially important. A motor rated at 95% efficiency can still waste energy if its gearbox operates far below its design load. Real losses matter.

Compare gear type, ratio, thermal capacity, and measured efficiency at your actual operating point. A supplier’s peak figure may not represent acceleration, frequent reversing, or continuous duty. I would not trust a single catalog percentage. Ask for test conditions, lubrication details, and permissible backlash. Spur gears can be economical, yet they may produce more noise at higher speeds. Planetary units offer compact torque density, but their precision can increase cost and maintenance demands. The imperfect choice is often the oversized motor that runs inefficiently every day.

Set Precision Targets for Backlash Below 10 Arcminutes

Choosing a precision gear motor starts with a clear backlash target. For many positioning systems, keep backlash below 10 arcminutes. One arcminute equals one-sixtieth of a degree. At a 100 mm radius, 10 arcminutes can create nearly 0.29 mm of angular error.

Define the real operating conditions before comparing specifications. Check load torque, speed, duty cycle, shaft orientation, and expected temperature changes. Measure backlash under the actual load, not only on a supplier’s test bench. Ask whether the stated value includes the motor, gearbox, coupling, and mounting structure. A low-backlash gearbox can still perform poorly if the coupling twists or the frame flexes. Small details matter.

Review seven practical points: backlash, repeatability, rated torque, speed range, thermal behavior, shaft stiffness, and feedback compatibility. Confirm whether backlash increases after wear or reversing direction. Use a test dial or encoder to record forward and reverse movement. Allow time for temperature stabilization. I once treated a cold measurement as final, and the result changed after continuous operation. That was a useful warning. Below 10 arcminutes is a target, not a guarantee. Specify the measurement method, load, temperature, and service life, then verify the complete assembly before production.

Precision Gear Motor Selection: Backlash Targets Below 10 Arcminutes

Recommended maximum backlash targets for common motion-control applications. Lower values generally improve positioning accuracy, contouring performance, and repeatability.

Backlash is shown in arcminutes (1° = 60 arcminutes). Treat these values as practical design targets; confirm the final requirement using the complete mechanical system, load, speed, encoder resolution, and duty cycle.

Match Duty Cycle, IP Rating, and Operating Temperatures to the Application

7 Tips for Choosing the Right Precision Gear Motor?

A precision gear motor should match the machine’s real workload, not just its peak torque. Check the duty cycle: continuous, intermittent, or frequent starts and stops. A motor running for ten seconds every minute faces different thermal stress than one operating all day. Record load, speed, acceleration, and daily operating hours. Small errors here can cause large sizing problems.

IP rating matters where dust, washdown spray, or humidity is present. An enclosed motor may protect internal parts, but seals can still weaken under repeated cleaning. Do not choose an IP rating from habit. Study the actual exposure, fluid temperature, and cleaning pressure. Operating temperature also changes lubricant behavior and winding performance. Cold environments can increase starting resistance. Hot enclosures may require torque derating or forced cooling.

I once focused too heavily on rated torque and overlooked the machine’s stop-start pattern. That choice looked acceptable on paper, but the housing became warmer than expected. Measure temperature during a full production cycle. Leave a practical margin, without oversizing blindly. An oversized motor can reduce control quality, waste energy, and increase cost. Ask for test data, verify shaft loads, and compare the motor’s thermal limits with the application’s worst realistic conditions. Check the datasheet twice.

Verify Supplier Testing for Life Ratings Exceeding 10,000 Operating Hours

When choosing the right precision gear motor, supplier life testing deserves close attention. A rating above 10,000 operating hours sounds impressive, but the test setup matters more. Ask whether motors ran continuously, under rated torque, or through realistic start-stop cycles. The setup matters. Request details about voltage, speed, load, ambient temperature, lubrication, and gear orientation. These conditions can change wear dramatically. A motor tested lightly may appear excellent.

Reliable suppliers should provide test dates, sample sizes, failure criteria, and performance trends. Look for records covering torque output, current draw, noise, backlash, and temperature. One sample is insufficient. Multiple units reveal variation between gearboxes. Independent laboratory involvement adds confidence when methods and calibration practices are clearly explained. A laboratory logo alone proves little. Ask how failures were recorded and whether testing stopped before wear became unacceptable.

For equipment running ten hours daily, 10,000 hours equals nearly 1,000 days of operation. This calculation connects laboratory results with field planning. Confirm whether the rating includes maintenance intervals and allowable performance loss. Check warranty terms, replacement procedures, and test similarity to your application. Start with evidence. In practical evaluations, I prefer a documented endurance report over a polished sales chart. I may miss something. Heat, misalignment, and contaminated air can shorten service life quickly. A small pilot run under actual duty conditions can expose those weaknesses before full deployment.

FAQS

What information should I collect before selecting a precision gear motor?

Record moving mass, friction, incline, speed, duty cycle, and shock loads. Measure torque at the output shaft. Include acceleration and steady operation. A 40-kilogram conveyor at 30 revolutions per minute needs careful gearing.

How much service factor should I apply to calculated torque?

Use a 1.5–2× service factor for ordinary uncertainty. It helps cover starts, brief overloads, wear, and imperfect assumptions. Frequent reversals or sudden jams may require more analysis. The spreadsheet can still be wrong.

Should continuous torque and peak torque be checked separately?

Yes. Continuous torque describes sustained operation. Peak torque covers starts, reversals, and short overloads. Confirm that the gearbox survives peak loads without excessive backlash. Leave space for temperature rise.

What backlash target suits many positioning systems?

A practical target is below 10 arcminutes. At a 100-millimeter radius, this may create nearly 0.29 millimeters of angular error. Measure under the real load. Do not trust a number without its test method.

Can the coupling and frame affect positioning accuracy?

Yes. A flexible coupling can twist during reversal. A weak frame can bend under load. These effects may hide the gearbox’s actual performance. Check the complete assembly with a test dial or encoder.

Which specifications should I compare besides backlash?

Compare repeatability, rated torque, speed range, thermal behavior, shaft stiffness, and feedback compatibility. Check whether backlash increases after wear. Temperature changes matter. Small details become visible during long operation.

What should I ask about a claimed service life above 10,000 hours?

Ask about torque, speed, voltage, temperature, lubrication, orientation, and duty cycles. Request sample sizes, failure criteria, test dates, and performance trends. Check noise, current, temperature, backlash, and torque records. One sample proves little.

How can laboratory life ratings relate to actual equipment use?

Ten thousand hours at ten hours daily equals nearly 1,000 operating days. Real conditions may include heat, misalignment, and contaminated air. Run a pilot under actual duty conditions. Field data is messier.

Conclusion

Choosing the right Precision Gear Motor begins with clearly defining the application’s load, speed, and torque requirements, while applying a 1.5–2× service factor to accommodate starting loads, variations, and long-term wear. Evaluate different gear types and reduction ratios based on the desired balance of output speed, torque, noise, size, and efficiency, which may range from approximately 70% to 95%. For applications requiring accurate positioning, establish a suitable precision target and consider designs with backlash below 10 arcminutes.

The motor should also match the application’s duty cycle, environmental protection needs, and operating temperature range. A proper IP rating can help protect against dust or moisture, while thermal compatibility supports reliable continuous operation. Finally, review the supplier’s testing and documentation, including life ratings that exceed 10,000 operating hours under defined conditions. By assessing these factors together, users can select a reliable, efficient, and durable solution that meets both performance and maintenance expectations.
Oliver

Oliver

Oliver is a seasoned marketing professional with a wealth of expertise in driving brand awareness and engagement. With a deep understanding of our company's product offerings, he consistently delivers high-quality content that enriches our professional blog. His insights not only shed light on......